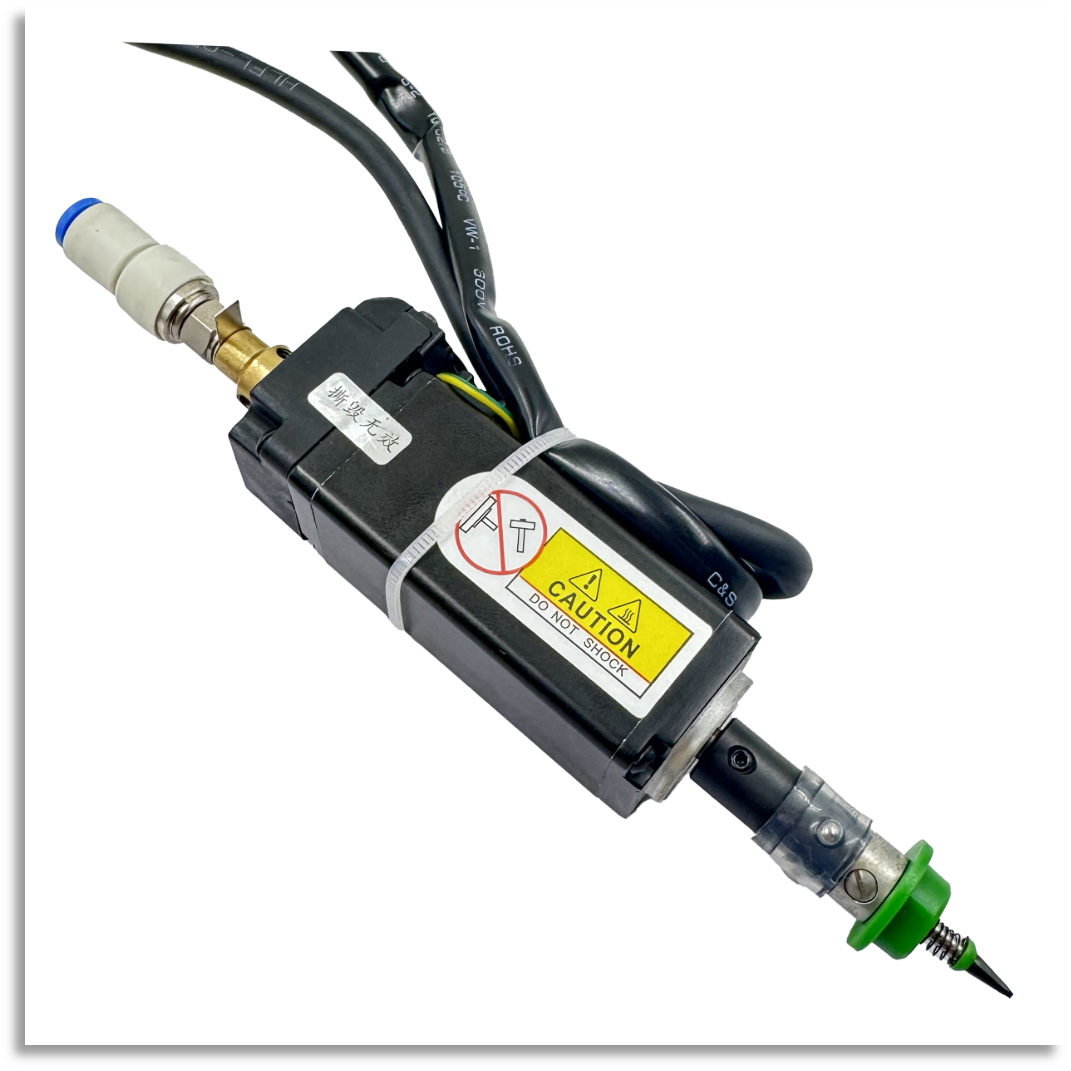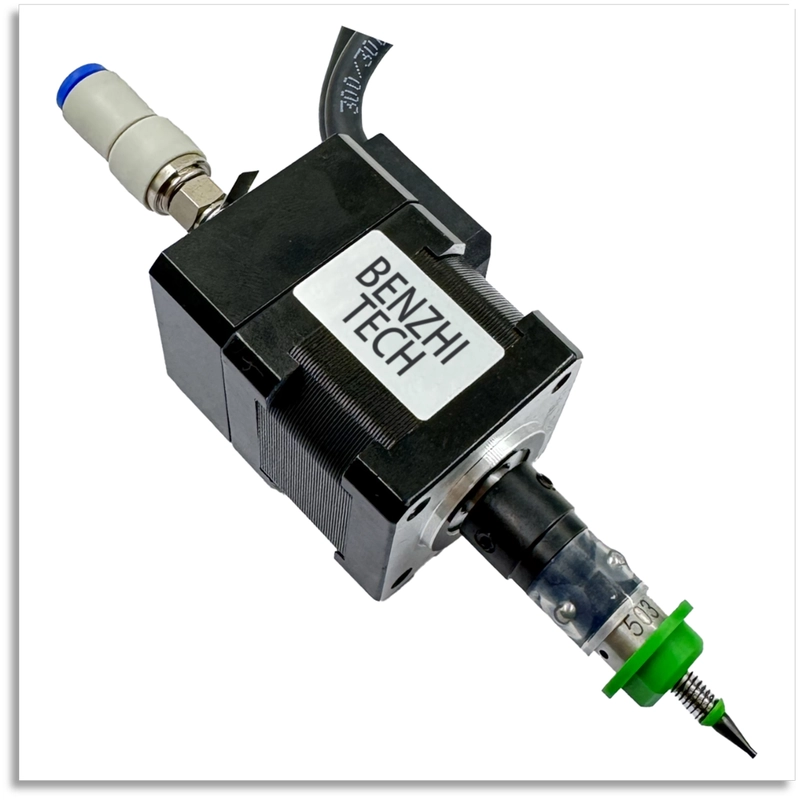
SMT Pick and Place Multi-Station Head Module BT407
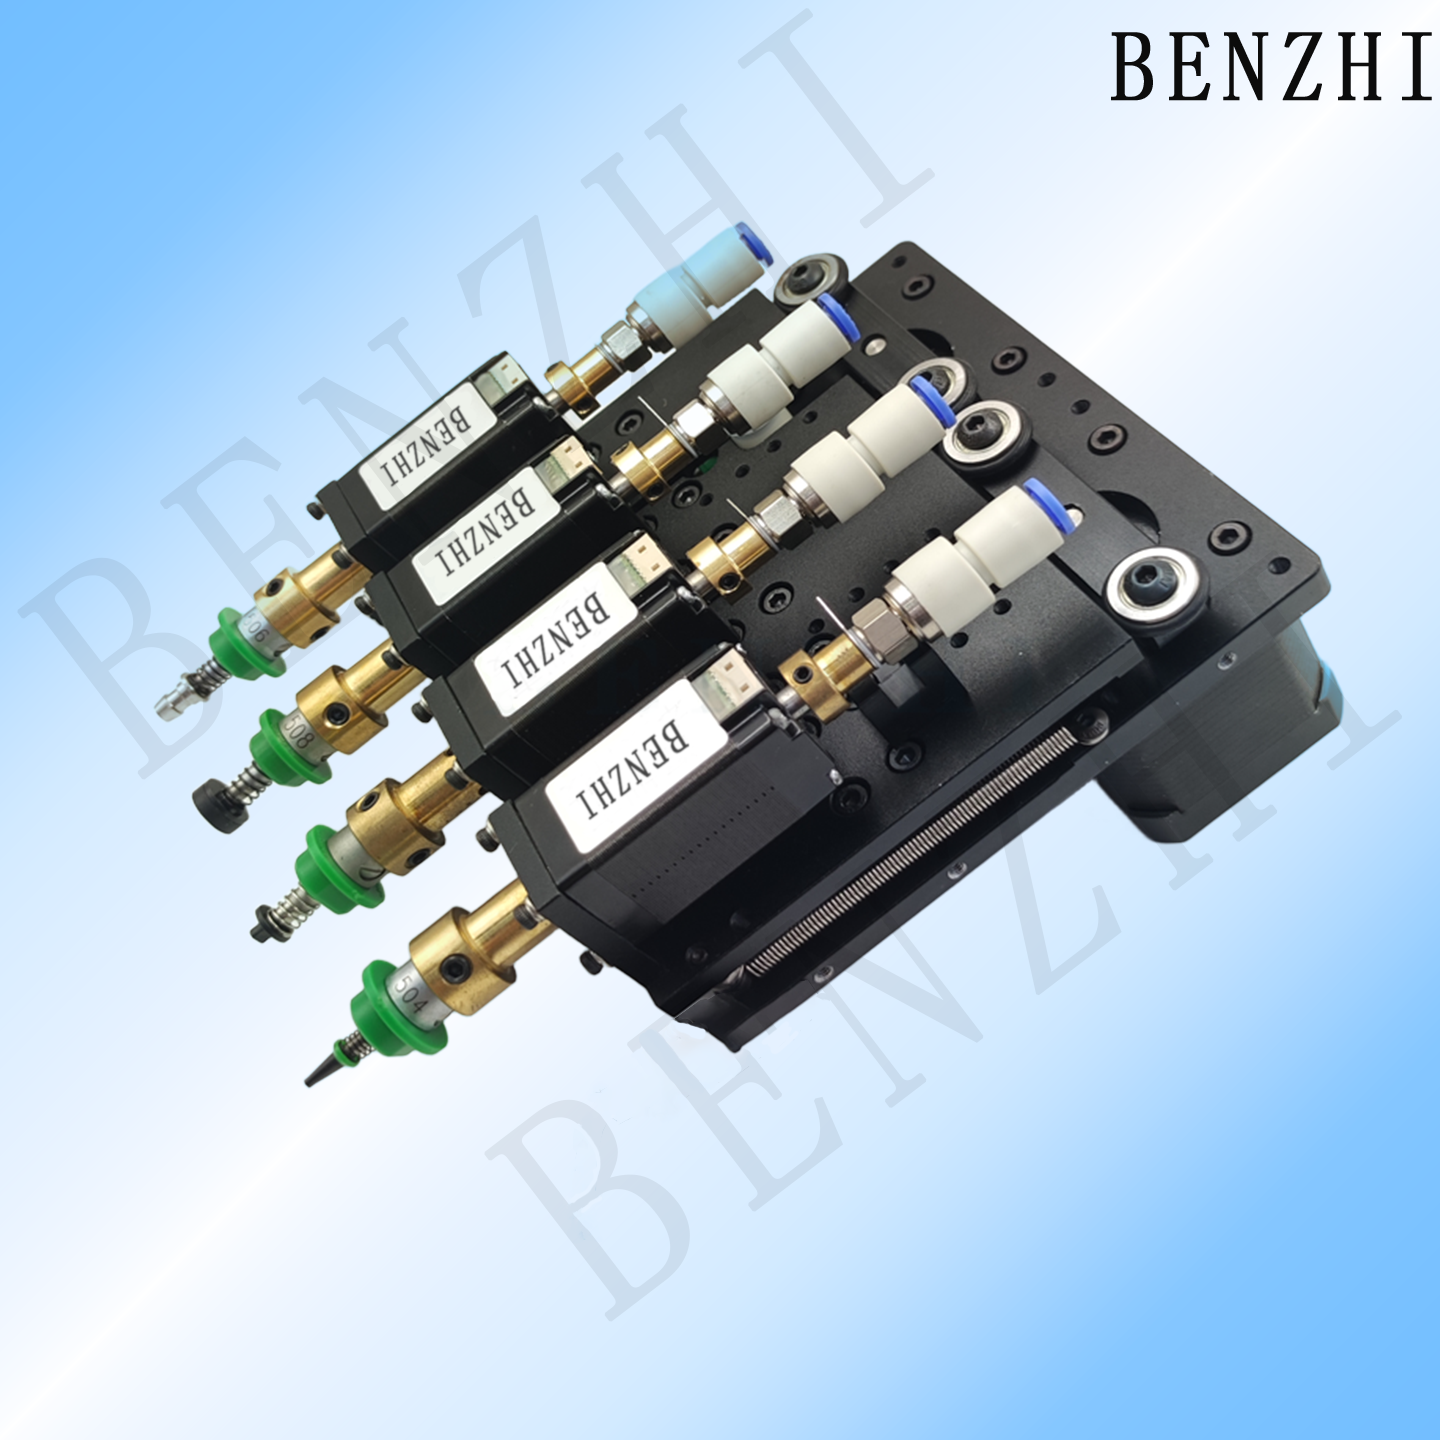
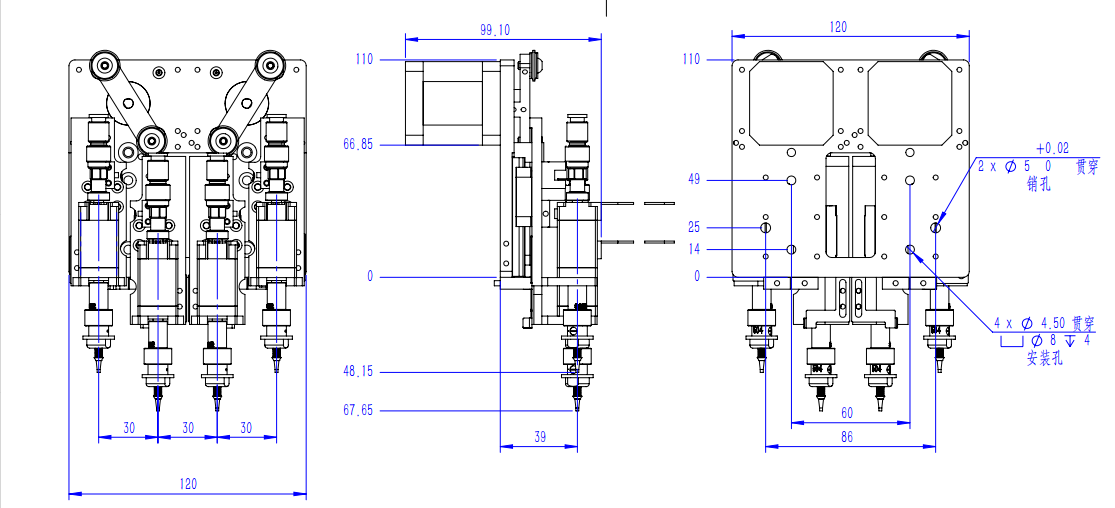
Featuring a 4-station design, this pick and place head delivers rapid loading and unloading cycles, offering excellent durability and great value for money.
Z-axis maximum speedreciprocating in 0.28 seconds
R-aixs concentricity0.05 - 0.2 mm
Vertical repeatability0.05 mm
Maximum vertical stroke range19.5 mm
Net weight1800 g
Motor frame diameter20 mm
Warranty12 months
Lead time5-7 days
Functions and features:
1. Z-axis vertical movement
2. 360° rotation on the R-axis
3. Vacuum suction and vacuum breaker
4. 4-Head, 4-Station Design
5. R-axis is optional with various models of 20mm hollow-core motor
Key parameters:
1. Pitch: 30 mm
2. Z-axis maximum speed: reciprocating in 0.28 seconds
3. R-aixs concentricity: 0.03 mm - 0.15 mm * decided by the configuration of the optional R-axis model
4. Weight: 1800 ± 50 g
5. Vertical repeatability: 0.05 mm
6. Maximum vertical stroke range: 19.5 mm
Stepper motor parameter
Step angle: 1.8° ±5%
Number of phase: 2
Phase voltage: 7.5 VDC
Phase current: 0.6 Amp
Phase resistance: 12.5 Ω ±10% (at 20℃)
Phase inductance: 5.5 mH ±20%
Insulation class: Class B
Insulation resistance: 100 MΩ min. (500 VDC)
Ambient temperature: -20℃ to +50℃
Ambient humidity: 15% to 95%
Motor weight: Approx. 80 g
Operating voltage: 12-24 VDC
| Pick and Place Head Specification | Value |
| Z-axis maximum speed | reciprocating in 0.28 seconds |
| R-aixs concentricity | 0.05 - 0.2 mm |
| Vertical repeatability | 0.05 mm |
| Maximum vertical stroke range | 19.5 mm |
05 / Engineering Matching
Need the module adapted to your workpiece or machine layout?
We can support a configuration discussion around nozzle geometry, connecting bar structure, vacuum pickup conditions, Z-axis travel, R-axis motor selection, mounting holes, cycle expectation and multi-station requirements.
01Send the requirementPart drawing, dimensions, material
and target process
02Review the motion configurationStroke, rotation, vacuum
and installation matching
03Confirm tooling & solutionNozzle, connecting bar and
integration details
06 / Related Products
Build a complete pickup and placement assembly.
Combine the ZR module with matched tooling, placement heads and multi-station modules according to the process layout.